Concepts of Stability Introduction
Introduction to Stability in Control Systems
Understanding Stability
- The term stability refers to the stable working condition of any control system, which is essential for proper design and functionality.
- A system is considered stable if its output remains predictable and bounded for any given input; otherwise, it is deemed unstable.
Definitions of Stability
- Key definitions include:
- Asymptotic Stability: Output tends to zero without input, regardless of initial conditions.
- Limited Stability: Output has constant amplitude oscillations under certain constraints.
- Absolute Stability: Output remains stable across all variations of inputs.
- Conditional Stability: Output is stable only within a limited range of parameter variations.
Bounded Input Bounded Output (BIBO) Stability
- A linear relaxed system exhibits BIBO stability if every bounded input results in a bounded output.
- For a system to be BIBO stable, the impulse response must be absolutely integrable.
Characteristics Equation and Poles
Closed Loop Transfer Function
- The closed loop transfer function is defined as the ratio of two polynomials in 's', where the denominator represents the characteristics equation.
- The roots of this characteristics equation are known as poles, which determine system stability based on their location in the s-plane.
Conditions for System Stability
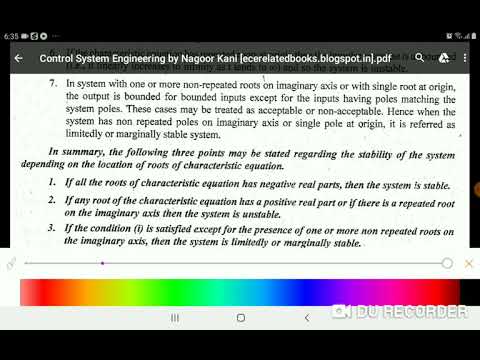
- Three key conditions regarding pole locations:
- If all roots have negative real parts, the system is stable.
- If any root has positive real parts or there are repeated roots on the imaginary axis, the system is unstable.
- Presence of non-repeated roots on the imaginary axis indicates limited or marginal stability.
Coefficients and Their Impact on Roots
Analyzing Coefficients
- If all coefficients of a characteristics polynomial are positive and none are zero, then all roots lie in the left half of the s-plane.
- Any coefficient equal to zero may place some roots on the imaginary axis or right half plane, indicating potential instability.
Necessary Conditions for Stability
- All coefficients must be positive for stability; however, this alone does not guarantee that all roots will have negative real parts.
Routh-Hurwitz Criterion
Analytical Procedure for Root Determination
- The Routh-Hurwitz criterion provides an analytical method to determine whether all polynomial roots have negative real parts by examining its characteristics equation.
Steps for Analyzing System Stability
- Begin with identifying characteristics equations from transfer functions; ensure that all coefficients are positive as a necessary condition for stability.
- Positive coefficients do not guarantee stability since some roots may still lie in undesirable regions (right half-plane or imaginary axis).
Constructing Routh Array
Route Array Construction Methodology
- To construct a route array from a characteristics equation:
- Start with s^n , followed by decreasing powers down to s^0 .
Conditions Based on Route Array Elements
- The first column's elements must be positive; if not met, declare instability. Sign changes indicate how many roots exist in the right half-plane.
Cases in Route Array Analysis
Identifying Different Cases
- There are three important cases when constructing route arrays:
- Case 1: Normal route array with non-zero elements.
- Case 2: A row consisting entirely of zeros.
- Case 3: First element zero but other elements present.
This concludes an introductory overview aimed at understanding critical concepts related to stability within control systems. Further videos will delve into specific examples and detailed case studies.
Turn any video into a summary like this
YouTube links, meetings, lectures. With transcripts, search, and chat.